Philo from France, well-known for numerous great NXT creations and as an author of many LDraw files, has updated the web page for his NXT-3D Laser Scanner. The Scanner is able to create three-dimensional computer models of things it scans with a laser:
Amongst other things, Philo uses it to create LDraw models for new LEGO® parts.
Showing posts with label philo. Show all posts
Showing posts with label philo. Show all posts
Sunday, November 21, 2010

Saturday, February 27, 2010
Another way of using the Power Functions remote handset to control the NXT

"The idea is simple: combine the outputs of the PF receiver with well chosen resistor values to obtain a different voltage for each combination of controls and measure this voltage with the NXT."
Yet, you need to do some soldering inside of the PF receiver for that.
Sunday, December 27, 2009
Philo's Fast NXT 2.0 Ball Sorter
My good friend Philo, who designed and build the robotic arm as a extra model for the NXT 2.0 box, build and FAST ball sorter.

Here is a movie:
Philo also made great Building instructions at his homepage.
Thanks Philo for this nice creation, I'm looking forward for the first implementation inside a GBC.

Here is a movie:
Philo also made great Building instructions at his homepage.
Thanks Philo for this nice creation, I'm looking forward for the first implementation inside a GBC.
Saturday, November 14, 2009
Color Sensor Comparision
 Philo has just put up a really well-done comparison of two of the color sensor that are currently available for the NXT. The first is the official one from LEGO, included in the V2 NXT kit, while the second is the HiTechnic V2 color sensor which can be purchased separately. I'm not going to bother summarizing Philo's excellent presentation too much, because reading it is an education in itself - not just on how the sensors "perform", but on how to compare sensors properly: developing tests, and understanding the results. Please read his page for the whole scoop. A dirt-simple summary is both have strong points, with the HiTechnic one being amazing at detecting multiple colors and handling challenging ambient light conditions, and the LEGO one (by virtue of using the rapidly-reading AtoD converter on-board the NXT) being much faster (probably important for line-following, for instance).
Thank you Philo for doing comparisons like this - and please read his summary, it really is excellent.
Monday, March 16, 2009
NXT 3D Scanner
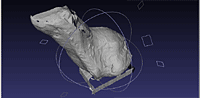
MCP Philo, well known for a lot of exciting robots, deep insight into the NXT internal electronics and as author of many LDraw parts and of a NXT book (just to name a few things), has published a new fascinating device: a NXT-based 3D scanner.
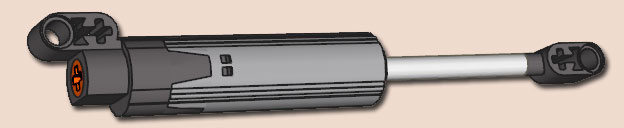
It scans small objects using a needle mounted on a LEGO® linear actuator and reports the data to a computer where they can be used to generate a related 3D CAD model:
Intriguing!
Note that the scanner has been programmed with pbLua, the NXT programming language based on Lua.
A lot of more information can be found on the associated web page.
Monday, January 19, 2009
Software tools for legacy MINDSTORMS products
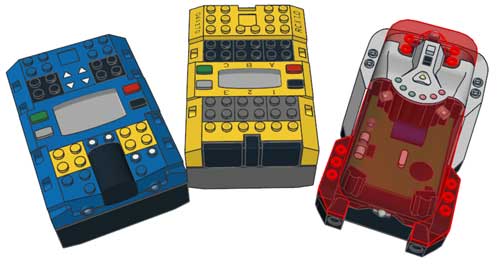
Philo, the new (well-deserving) lauréat of the James Jessiman Memorial Award of ldraw.org, has published a site where you can download the tools for the legacy MINDSTORMS products that LEGO® has stopped supporting: RCX™, Scout™ and Spybotics™.
LEGO® removed these tools from their web site in 2008, so this site of indefatigable Philo will be welcome by all the people that are still developing for these products.
It features
- the MINDSTORMS SDK 2.5
- updated USB tower drivers
- RIS 2.0 XP patch
Saturday, January 3, 2009
Treads available for LDraw

Philo, MCP and relentless Wizard of LDraw parts, has published LDraw files for the treads contained in the NXT Education supplemental kit (other configurations of the treads can be found here and here).
Hence you can model your NXT robots that run on these treads now in LDraw.
Thanks, Philo!
Tuesday, October 21, 2008
Odin, a robot for odometry
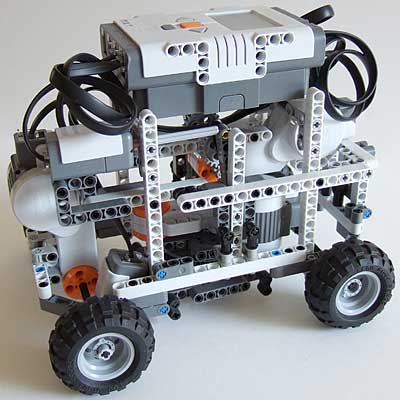
Philo, one of the European MCPs, has published a new robot for odometry, the art of estimating the own position during wheeled vehicle navigation. It's called Odin and
"it measures as precisely as possible distances travelled and orientation of displacement. Its mechanical structure is well suited for that: when travelling it rolls on four parallel wheel so it is able to go very straight. For turning, it raises itself on a central pivot, turns around it and goes down, ready for the next move", as the author states.
On the associated web site you'll find ample documentation, images, videos, programs and building instructions for it.
What's more: you can build it was one single NXT Retail kit!
Subscribe to:
Posts (Atom)