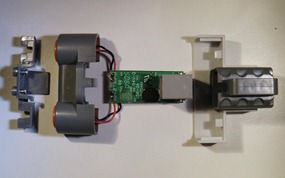
When I receive comments on my Youtube videos or someone subscribes to my channel I usually go visit their channel. I love it when I discover another NXT fan and find some amazing new creations. This situation happen to me recently when a comment from hydejump made me discover an interesting robot he is working on. It does not have a name yet, but the 16yo builder from Japan has posted several short video showing the progression of his work and programming.
I particularly like the video below showing how he used 2 Ultrasonic sensors side by side to have the head follow his hand!!
I have sent him a few emails in hopes to get more details of this really cool DALEK-ish looking bot with bubbly eyes. hydejump is new on YT but between his participation to WRO videos, his intriguing NXT snake video and his complex red robot, this is one channel I did not hesitate to subscribe to!!
NXT user Sean Corzine emailed me a picture and description of this nice modification to the 3-Speed Transmission with Clutch project on nxtprograms.com. His design adds the ultrasonic sensor to "see" the gearshift lever to determine which position it is in (high, medium, or low), then he added Math blocks to calculate the resulting output shaft speed based on the input RPM and gear ratio, and modified the NXT display to display output RPM instead of engine RPM.
This is a great example of using your available parts and some creativity to solve a problem, and it also reminds me of modern cars -- even in a modern manual transmission, the car's computer is always "watching" what you do in order to try to optimize fuel usage, minimize emmisions, etc. The manual transmission in the new Nissan 370Z even reacts during a shift to blip the engine RPM to match the new gear. Hmm..., anyone want to try adding that to Sean's idea?
After I insulted my NXT for being physically inferior to my cat in just about every way, it sulked back down to my den and contemplated its next move. Hey, what if it stole a play from the cat's book, and tried striking quickly with a claw?
This Claw Striker robot uses the ultrasonic sensor to turn around and locate a target, move to the proper range (forwards or backwards as necessary), then strike quickly with it's claw-tipped whip-like arm.
Here's a video. No, it's not brave enough to take on the cat yet, even if I would let it (please don't try with yours either).
This robot is from chapter 9 of the One-Kit Wonders book. If you watch the video, the robot may appear to be very simple. There are however, two things that make GrabBot special.
One of these two is the grabbing hand. Using one motor, it grabs and lifts object, which is a cellphone in this case.
The other is its autonomous behaviour. When I trigger the program to start by saying: "Get my cellphone", it starts searching for the closest object in range. While spinning around, it continously stores a sensor value along with a location in two variables. Then, it returns to the position where it measured the lowest sensor value and grabs the object.
When doing so many redaings from the Ultrasonic Sensor, it functions relatively accurate. It still has a few problems detecting balls, but if they're not too far away, it does find them.
P.S. Book reader Enrique has posted a call to action for One-Kit Wonders readers. Read it here.