Showing posts with label segway. Show all posts

Thursday, November 17, 2011

Segway Source code now available (dIMU and HiTechnic)

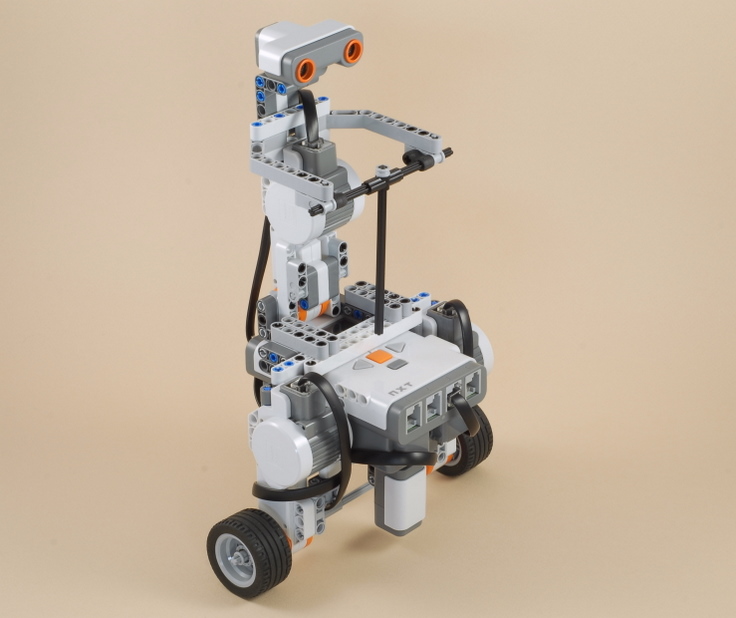
In the past few months I've been working on a renewed RobotC program for a LEGO MINDSTORMS NXT Segway.

The current program handles all balancing tasks in the background so you can make the Segway do what you want without worrying about balancing. It supports both the HiTechnic Gyro sensor and the new Dexter Industries dIMU. The complete source and instructions are available on my website.

The older ready to run NXT-G version of the program (only supports HiTechnic Gyro) is also still available.

Many of you have been asking for the source code, so here's a chance to study the balancing algorithm. You may use and edit the code as you like, but don't forget to link to the original code and give credit if you reshare your program.

Update: Just another example of what you could use the code for!

Monday, October 17, 2011

NXT Segway follows a line

A few days ago, I blogged about the progress on my NXT Segway with the Dexter Industries IMU. Here's a new video showing how it follows the line on the NXT Test Pad.

I will bring this robot to LEGO World (Netherlands) next weekend. Feel free to come by for a chat! We all speak Dutch and most of us speak Dunglish very well, too.

Friday, October 7, 2011

Segway balancing with Dexter Industries IMU Sensor


Recently I have been reprogramming my NXT Segway. The code is now much cleaner, and it also made it easier to implement Dexter Industries' latest sensor, the 6DOF IMU. The Segway runs around the room while avoiding objects with its ultrasonic sensor. This isn't new, but it's a nice demonstration of Dexter's new sensor.

In this robot I'm just using one "Degree of Freedom", namely one gyro axis. Other axes could be used for elementary navigation like making a 90-degree turn. The acceleration sensor could help determining whether the robot has run into an obstacle. Much interesting work left to do here!

Monday, June 6, 2011

Segway experiments

What do you do when you're in the MINDSTORMS booth at the FLL finals with plenty of robots around? Well, it might lead to some strange combinations. At some point I got the idea to combine a NXT Segway with omniwheels so that it could move sideways. In theory, this shouldn't have any influence on the robot's balance. See the practical experiment Xander and I did below.


Maybe I should patent the idea... If you motorize the sideway motion, Segways become even more capable of moving in narrow spaces.

Also, I wanted to try how well a Segway would perform on a randomly moving platform. This worked quite well, until you reach unexpected holes in the road. Pointless experiments, maybe, but certainly fun to do!

Wednesday, January 19, 2011

C-3PO Rides Lego Nxt-segway

Preeda form Thailand had to build this Classic rider, just for fun!


Nice work!

Monday, July 5, 2010

HiTechnic Balancing the HTWay


Sweet! HiTechnic's turn with HTWay ... a two-wheeled, self-balancing, Segway like marvel with a nice added feature...Power Functions remote control! At this point the HTWay requires a HiTechnic Gyro Sensor, a HiTechnic IRReceiver, and a LEGO Power Functions IR Remote Control. Programs for both NXT-G 2.0 and NXC are available. With the integrated wheel-size setting menu users have an interesting option. The provided programs can also be altered for exchange or integration of different sensors to fit specific needs.

HiTechnic has posted HTWay's detailed instructions (including building/ programming steps) and a nice back-history of self-balancing pBricks from the beginning. Be sure to see the video!

I've always loved the way 'AllTheseWays' look like nothing is happening when they are performing at their best...for me anyway...just standing there.

Chris

Sunday, June 20, 2010

Anyway Update

Based on feedback from NXT users, I have updated the programming instructions for the Anyway robot on my website. I have also updated the program. If you couldn't get your Segway to balance the first time you tried, please try again with the new program and the new instructions. More feedback is always welcome.

Monday, May 31, 2010

AnyWay -- Build a Segway in 30 minutes

Last Saturday, I blogged about a Segway programmed in NXT-G. Many NXT Segways out there work very well, but they're hard to get to work with common tools software. Therefore, I decided to create a step-by-step tutorial to making your own Segway with simple tools. All you need is Any version of the NXT set (Hence AnyWay), plus the HiTechnic Gyro Sensor. The tutorial can be found here, and a video of the robot is shown below.

Saturday, May 29, 2010

Segway in NXT-G

In the past year, a classmate and I have researched 'self-balancing robots' as a final year project. The goal was to create a simulation model of such a robot, and the result was an NXT Segway, with a HiTechic Gyro sensor, and programmed in RobotC (and a 170-page document going with it). I found this to be a very interesting project, but since the project document was written in Dutch entirely, that won't be very helpful to most of you.

Another Segway, you might think, and that's actually quite right. Today however, I wanted to try to program this Segway in NXT-G, because the current version of NXT-G (2.0) is relatively fast. It turns out that the Segway can still balance very well when programmed in NXT-G. It's a little slower, but it can still handle uneven terrain and small disturbances.

In the next week, I'll post some more updates, including the NXT-G program. Basically, all you need to create this robot is the HiTechnic Gyro sensor, any NXT set (any wheel size will work), and the NXT-G 2.0 software.

Wednesday, February 17, 2010

NXT 1.0 Segway with Rider

I have posted an NXT 1.0 version of the NXT Segway with Rider project (see previous blog entry on the NXT 2.0 version).

This version uses the standard light sensor instead of the color sensor, the taller balloon tires, and the NXT-G 1.x software (tuned for the 1.05 firmware). Although the control program runs significantly slower than the 2.0 version (the newer 2.0 software and firmware has reduced the overhead of the sensor and motor blocks considerably), the 1.x version fortunately is able to make up for it by using the light sensor's "Raw" output (not available on the 2.0 color sensor), which has much higher resolution, which makes it easier for the robot to maintain an accurate on-center position, despite the slower sampling rate.

So the best NXT-G configuration for this sort of task (or similar, think line following...) would actually be the NXT 2.0 software and 1.28 firmware but using the old light sensor in Raw mode, so you would get both the high speed and the high resolution. If anyone tries this starting from my programs, you will need to re-tune the PID gains to account for the higher sampling rate, since the calculations do not take into account the time slice...

Friday, February 12, 2010

NXT 2.0 - One Kit Segway


Dave over at www.nxtprograms.com recently put up instructions and programs for a Segway - built with a single NXT 2.0 set and programmed with NXT-G using a simple PID loop. Very cool!


Great job, and thanks!

Richard